Petit-Saut: 4,049 emerged stems located and measured in one LiDAR flying day
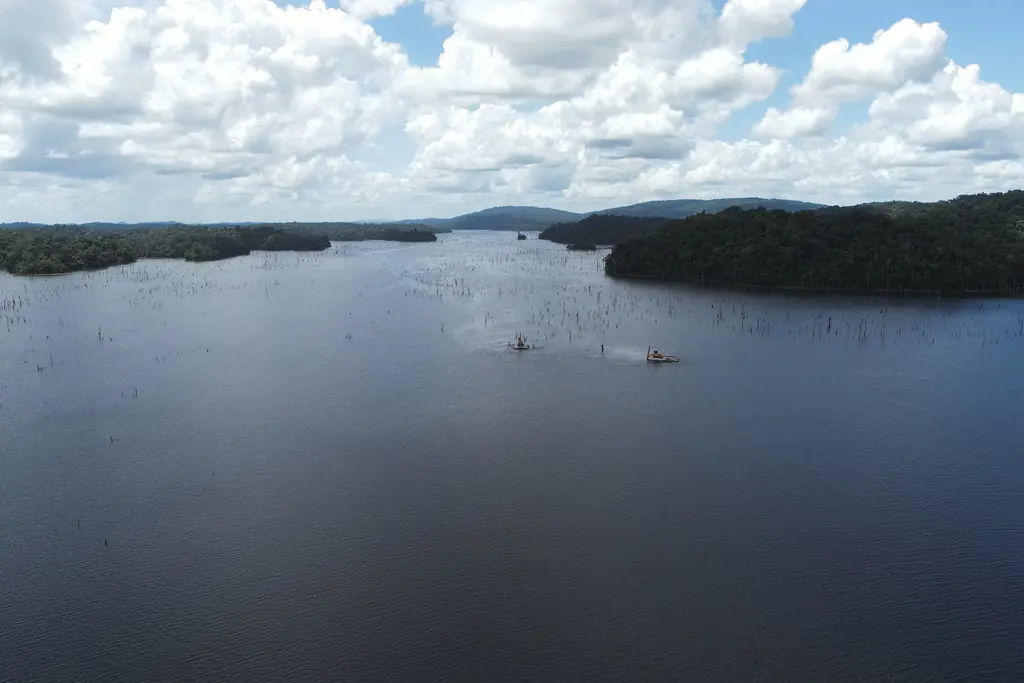
Since the Petit-Saut dam was impounded in 1994, thousands of dead trees have stood out of the reservoir. For a company planning to recover this timber, the first question is simple: how many trunks, where, and how big? In October 2026 we tested drone LiDAR and photogrammetry on a 46 ha block. Here is what we measured, what works, and what we recommend for the whole reservoir.
Counting and measuring what stands above the water
The forest was not cleared before impoundment. Thirty years later the dead trunks are still standing, and their emerged part is both a timber resource and a hazard to navigation. A timber company working on the reservoir asked us to test, on a representative block, what drone-borne sensors can deliver: a map of every emerged tree, its height above the water, its diameter if possible, and a comparison of the methods in quality and productivity.
The site sets the rules. No ground control point can be placed on water; the aircraft must stay within sight of the pilot; the reservoir level varies, and with it the number of visible trees. The 46 ha test block was chosen in a dense sector due for harvesting, so that the measurements can be checked on the trunks once they are cut.
One flying day, seven configurations
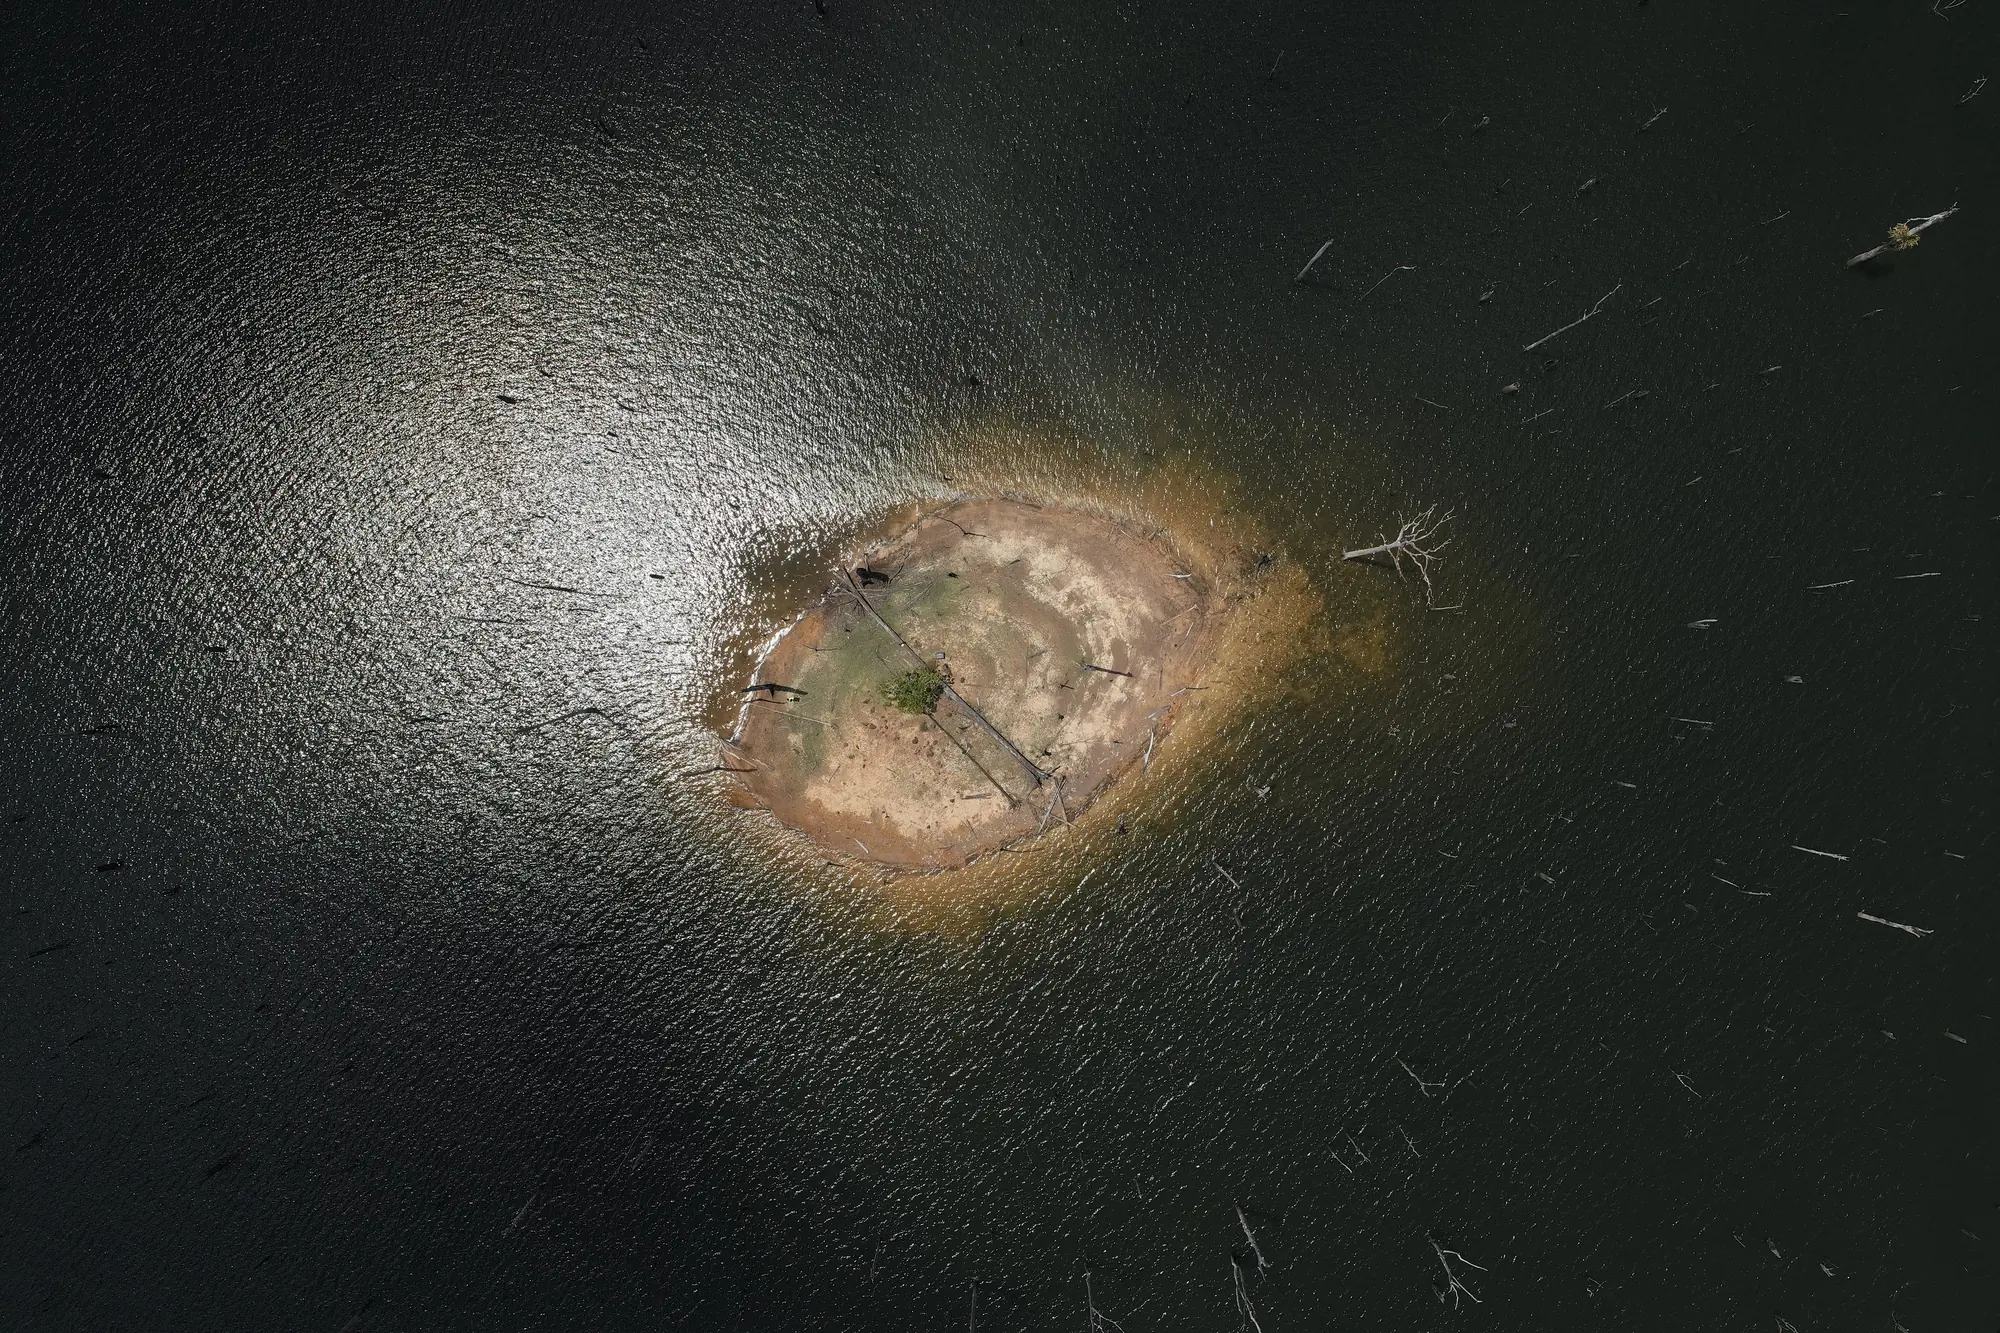
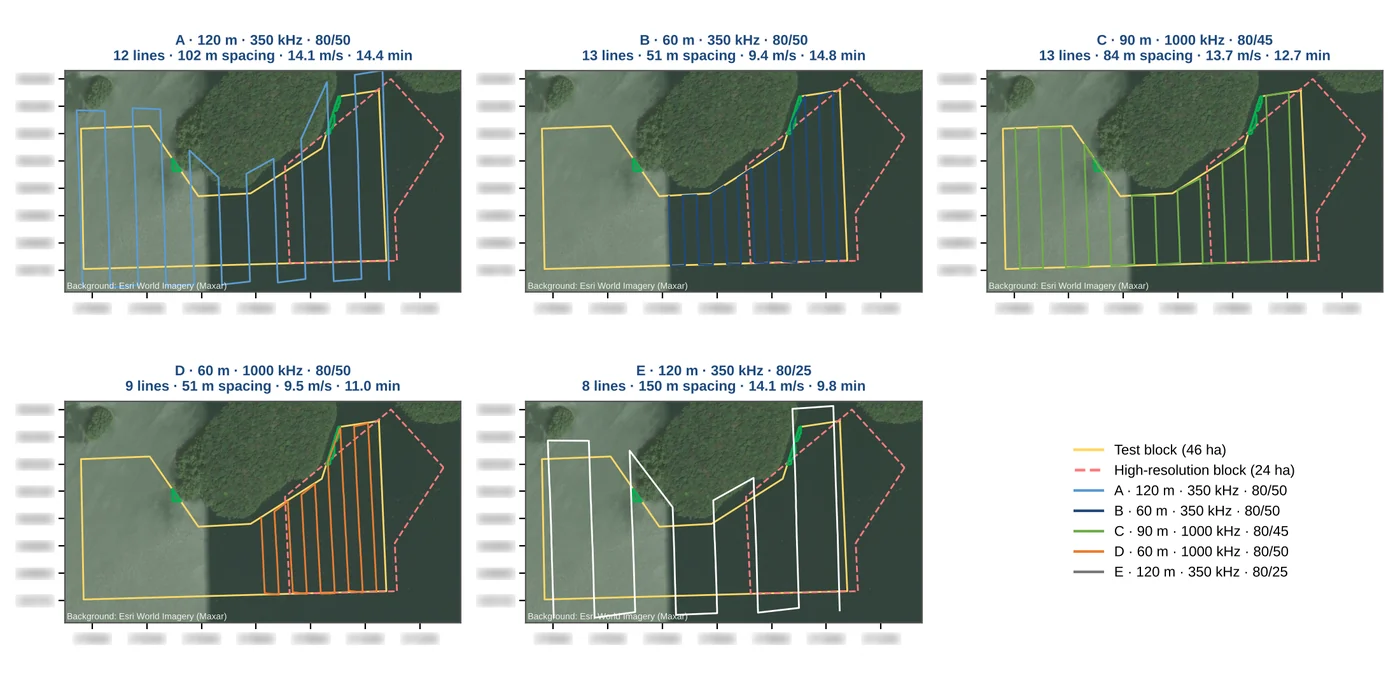
On 22 October 2026 a DJI Matrice 400 flew five LiDAR flights (Zenmuse L3) and two photographic flights (Zenmuse P1, 45 Mpx) from a small island in the middle of the stems, 450 m from the block. The LiDAR flights were made at 60, 90 and 120 m, at 350 or 1,000 kHz, with line spacings from 51 to 150 m: settings ranging from a detailed inventory, at 100 ha per flight hour, to fast reconnaissance, at 280 ha per hour.
With no ground control possible, positioning relies on a Trimble R2 GNSS reference station on land and on post-processed kinematic (PPK) trajectories. The water level is read directly in the point clouds: 31.10 m NGG77 that day, identical to within a few centimetres from one flight to the next.
What the LiDAR measured
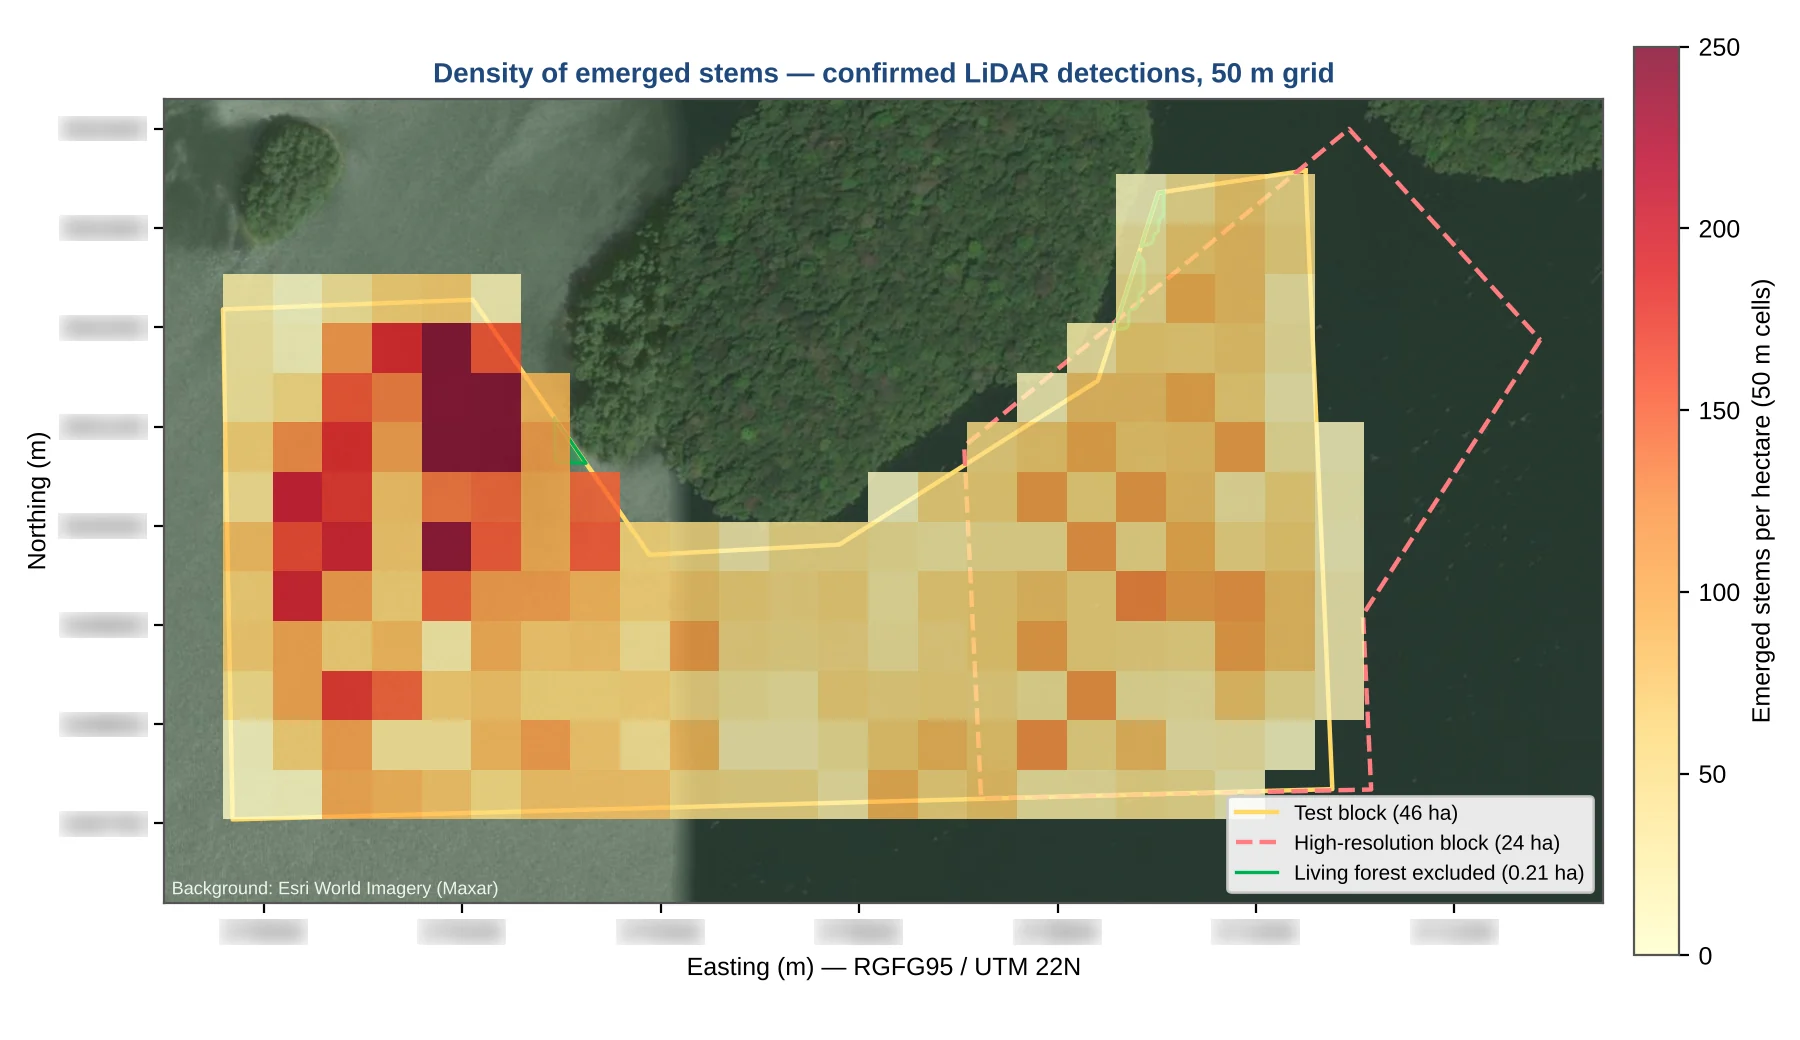
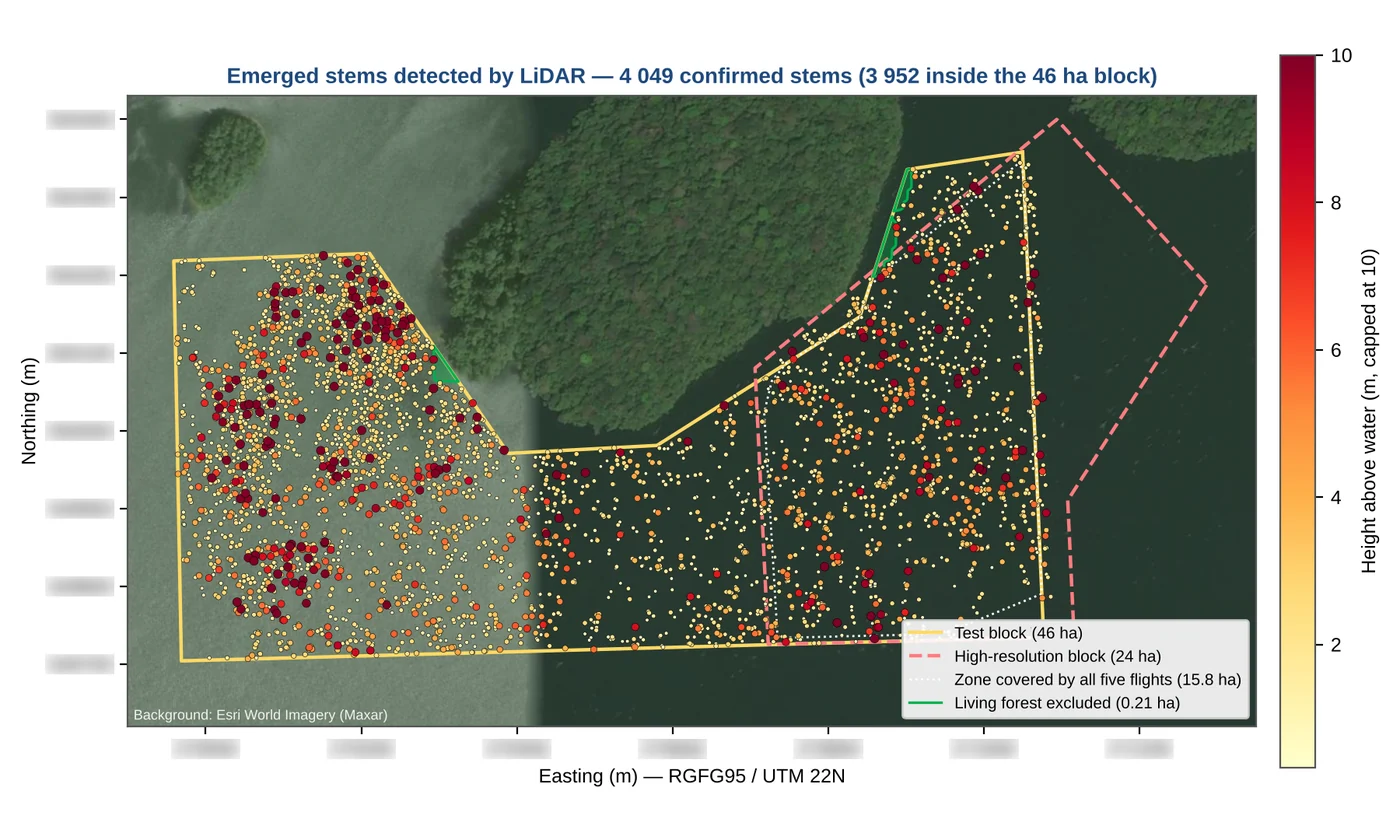
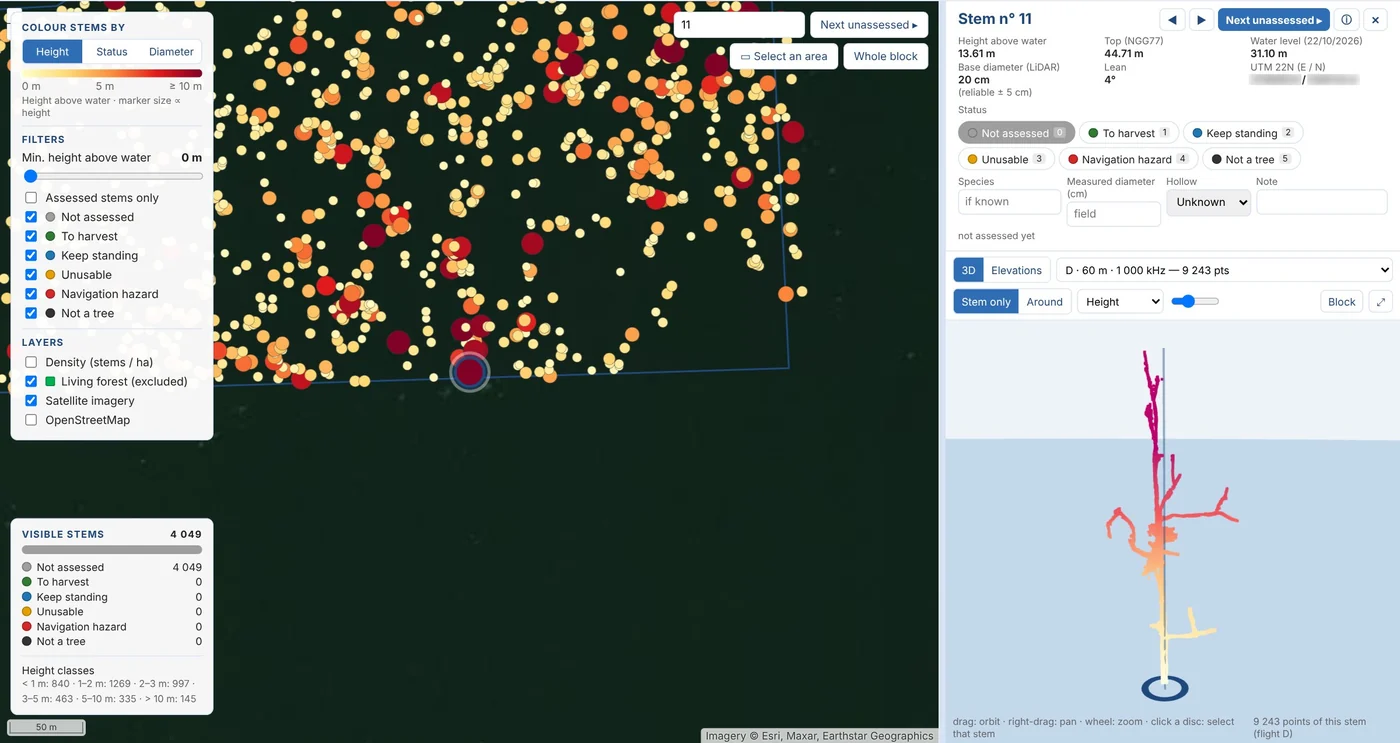
Laser returns above the water are grouped into objects; each object is a candidate stem, and a stem is confirmed when at least two flights detect it at the same place. The result: 4,049 confirmed stems, 3,952 of them inside the 46 ha block, i.e. 85 stems per hectare on average, with local densities from 4 to 300 per hectare.
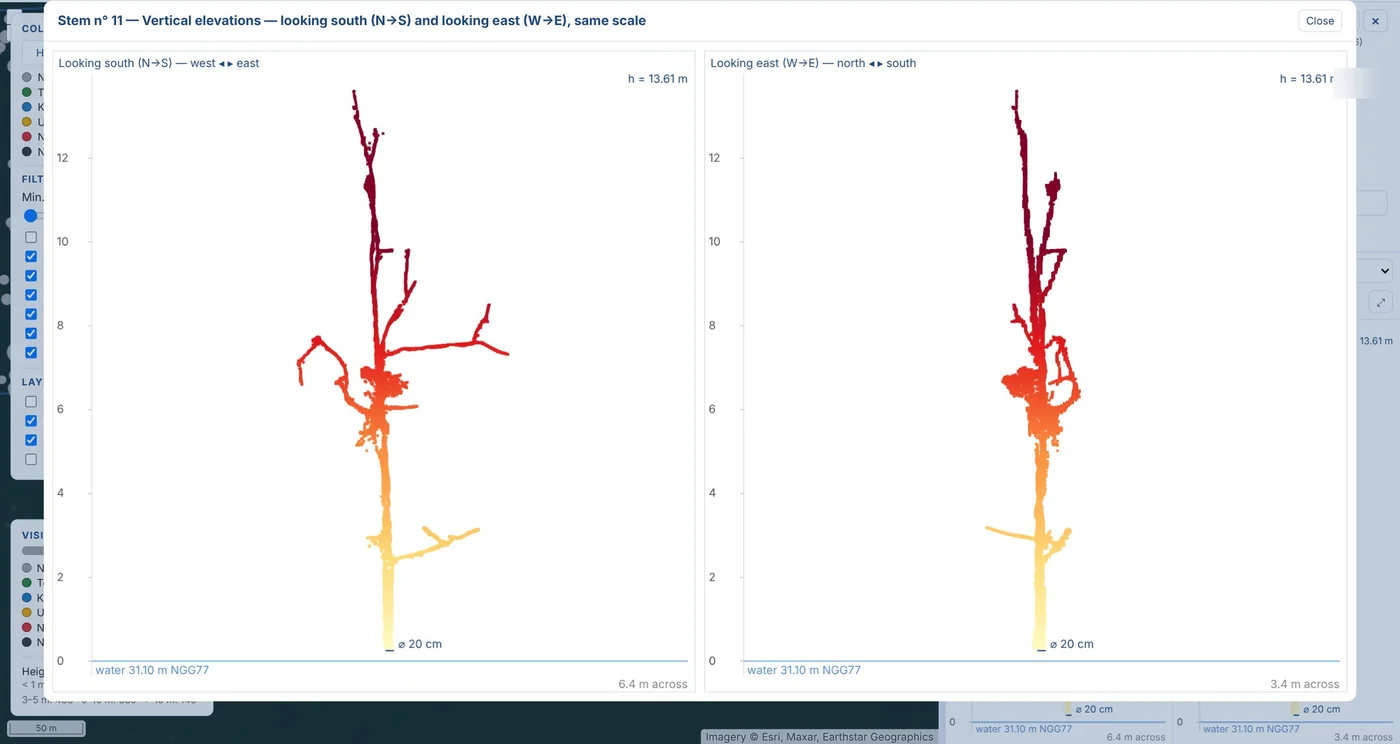
For each stem the height above water is measured: half of the stems emerge by less than two metres, 145 by more than ten metres, the tallest by 24.8 m. A base diameter is obtained for 88 % of the stems by fitting a circle to the trunk points just above the water line; for one third of them, two independent flights give the same diameter to within 5 cm.
Which flying height for which result
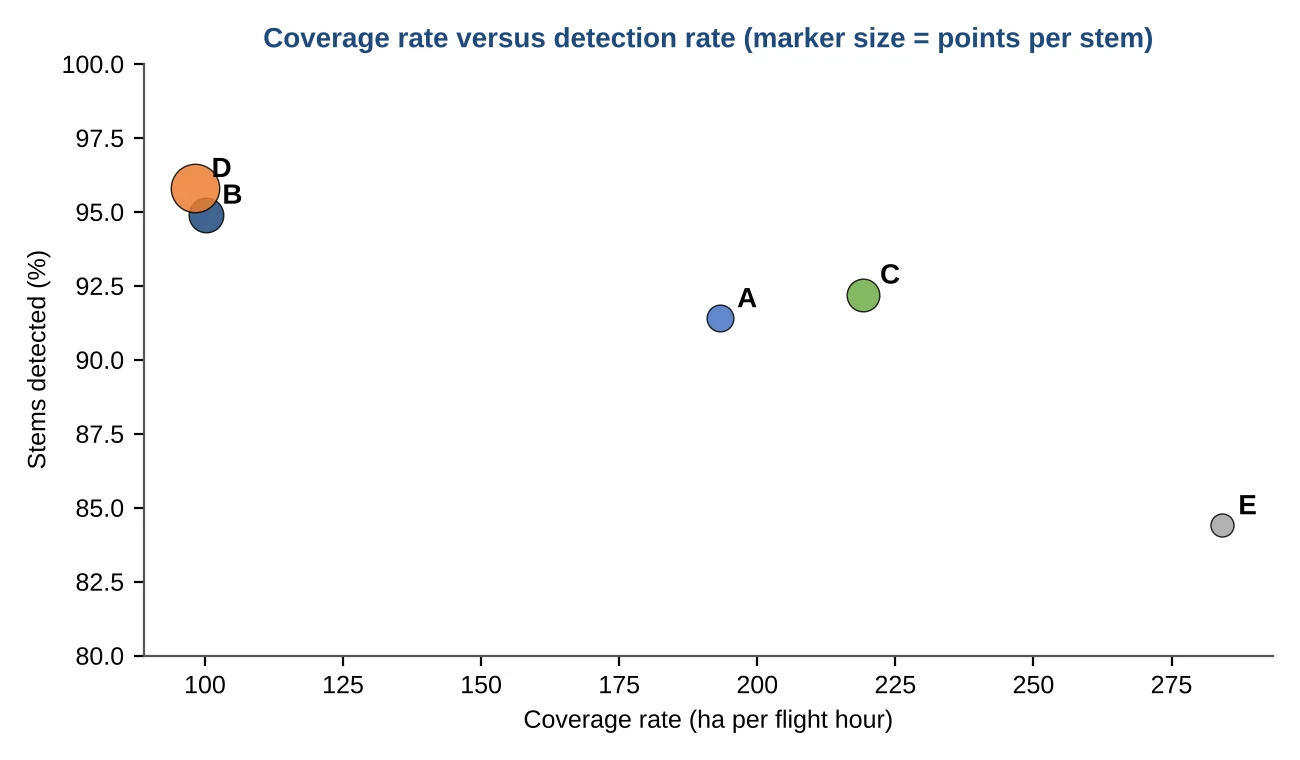
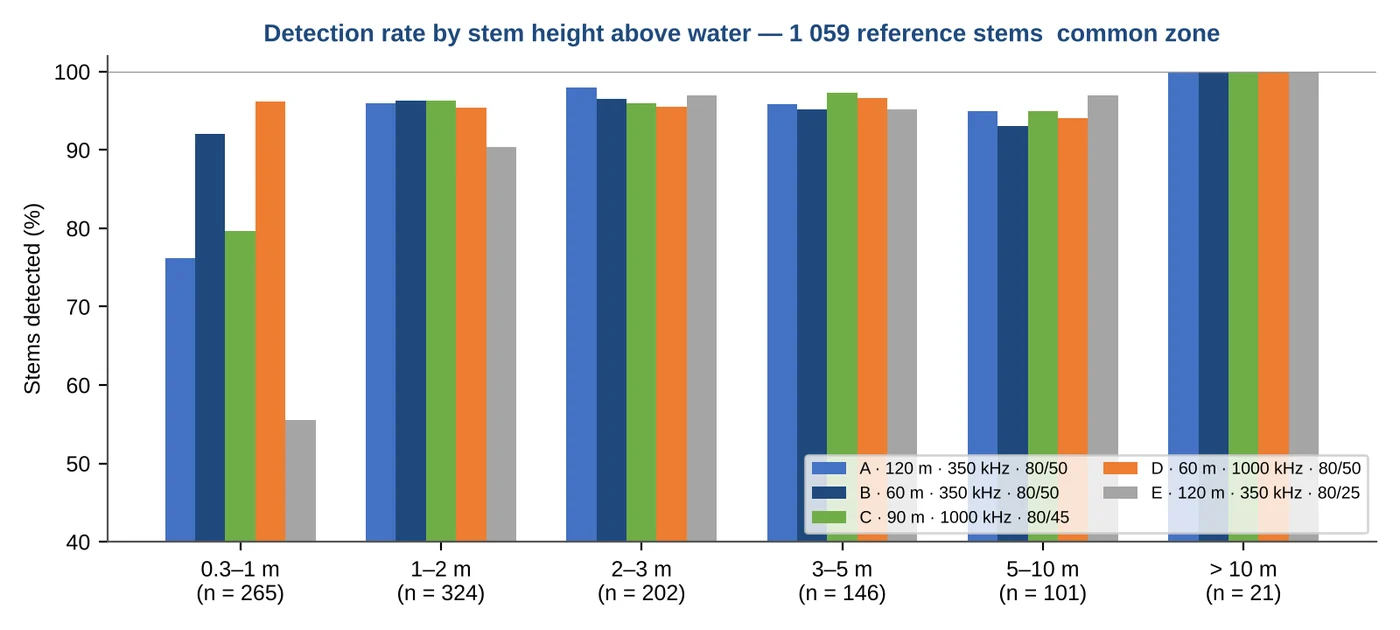
The five configurations were compared on the 15.8 ha covered by all of them. The two 60 m flights detect 95 to 96 % of the reference stems, the 90 m flight 92 %, the 120 m flights 84 to 91 % depending on the line spacing. The difference is concentrated on the stubs emerging by less than one metre; above one metre every configuration sees more than 90 % of them, and the heights agree to within 10 to 30 cm from one flight to another.
The number of points per trunk explains the rest: a median of 220 points at 60 m and 1,000 kHz, 82 at 90 m, 24 at 120 m with wide line spacing. With more points the diameter becomes measurable; with fewer points the coverage rate doubles.
Photogrammetry does not work over water
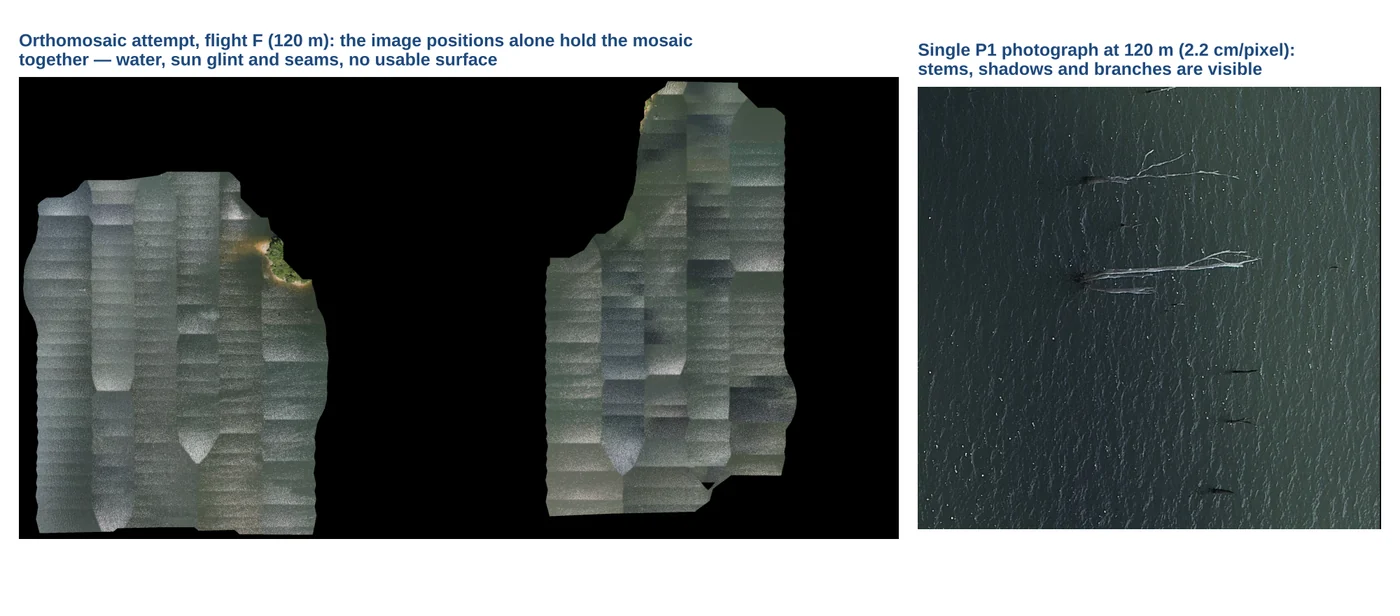
We also flew photographs at 60 and 120 m, with 65 % side overlap and oblique capture. No usable 3D model came out of it, neither in DJI Terra nor in Agisoft Metashape: the water surface moves between two exposures and reflects the sun, it offers no tie points, and the only fixed objects are trunks a few pixels wide. The photographs remain useful as a visual record, since at 2 cm per pixel every stem is visible with its shadow and branches, but the inventory itself does not need them.
Deliverables that can be used the same day
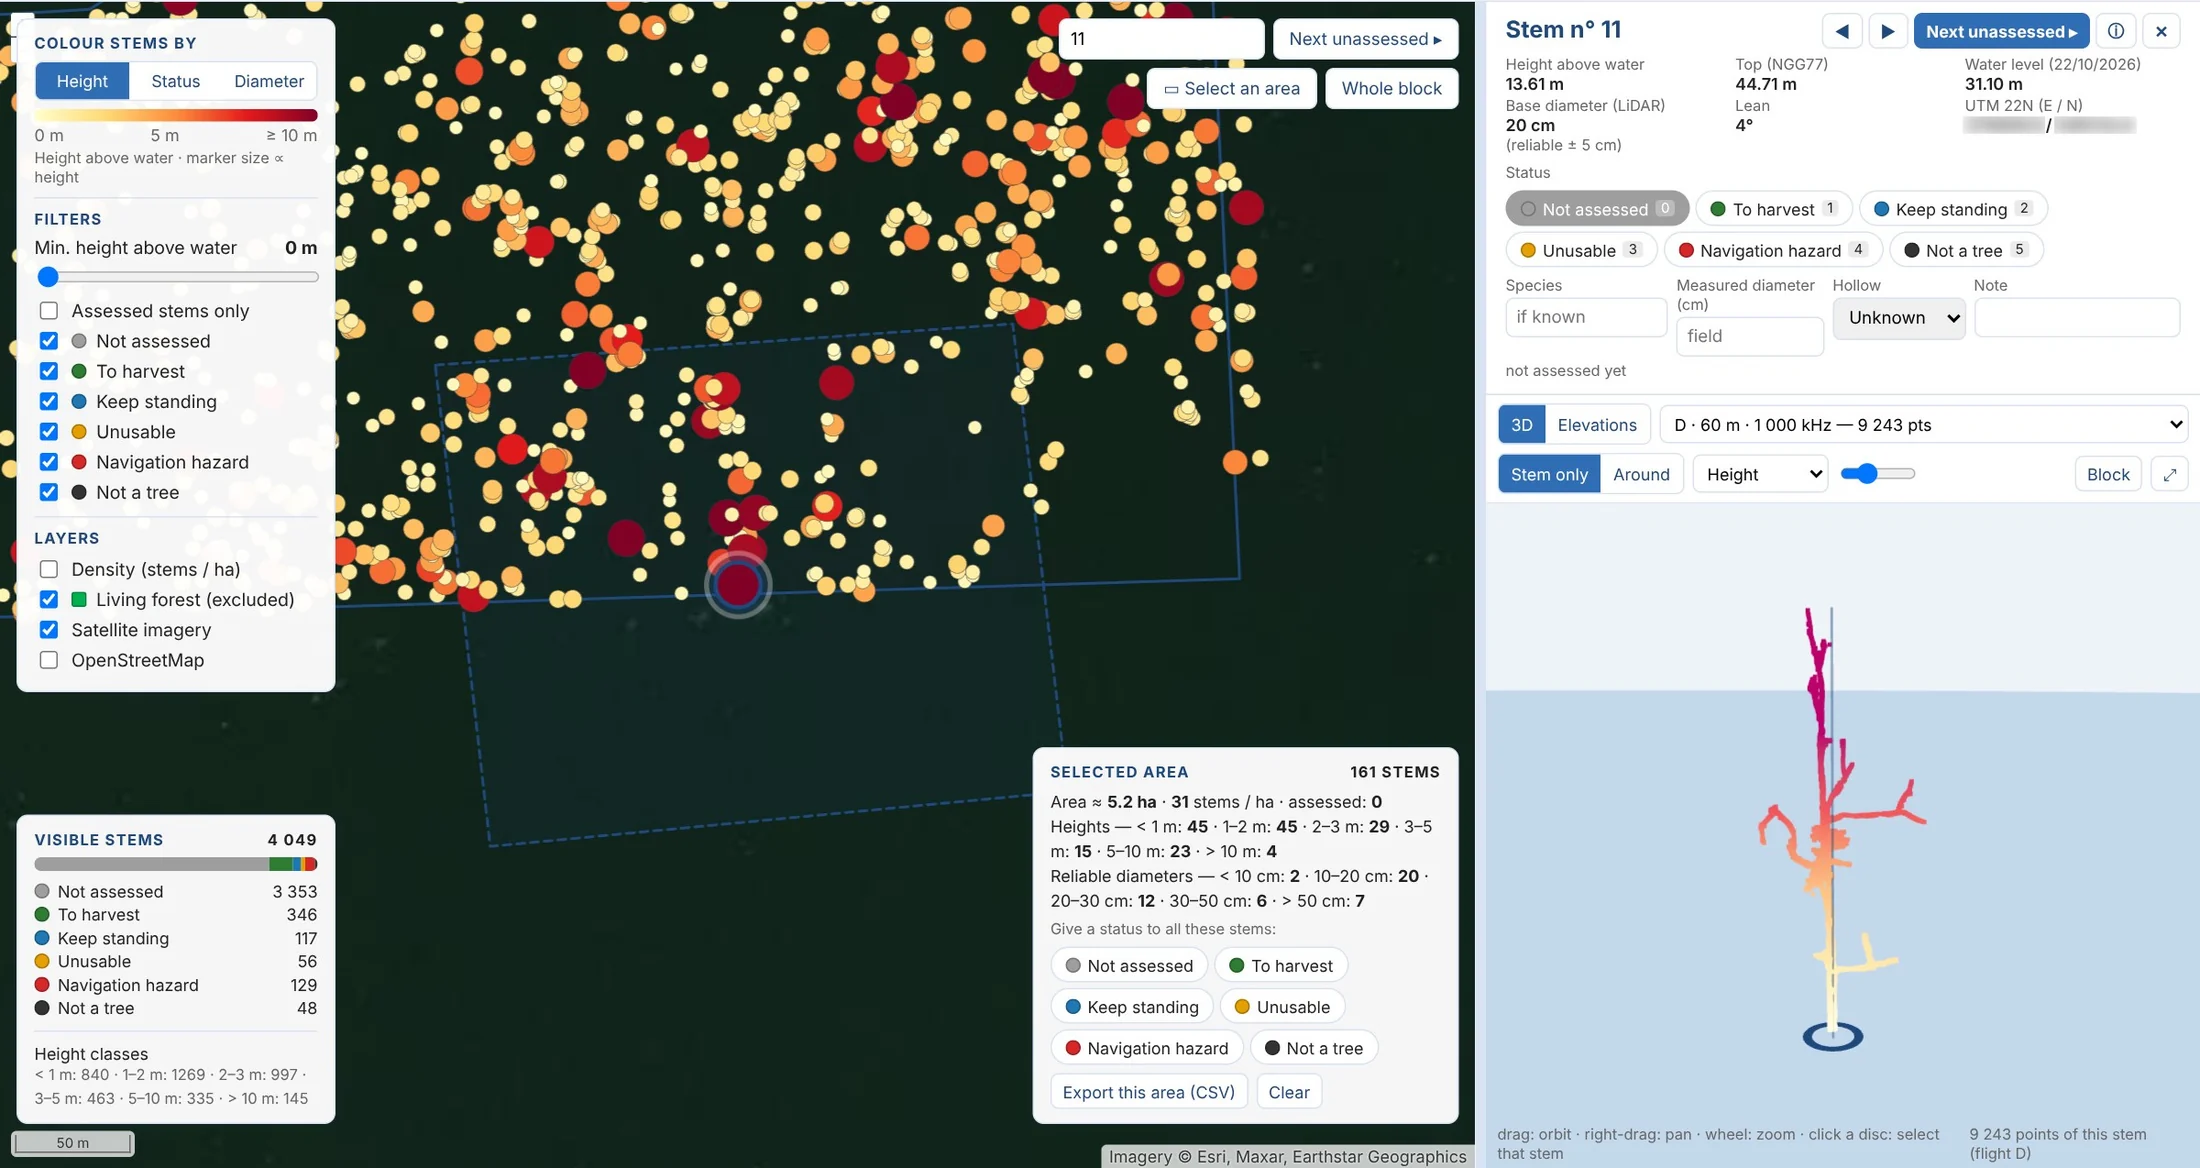
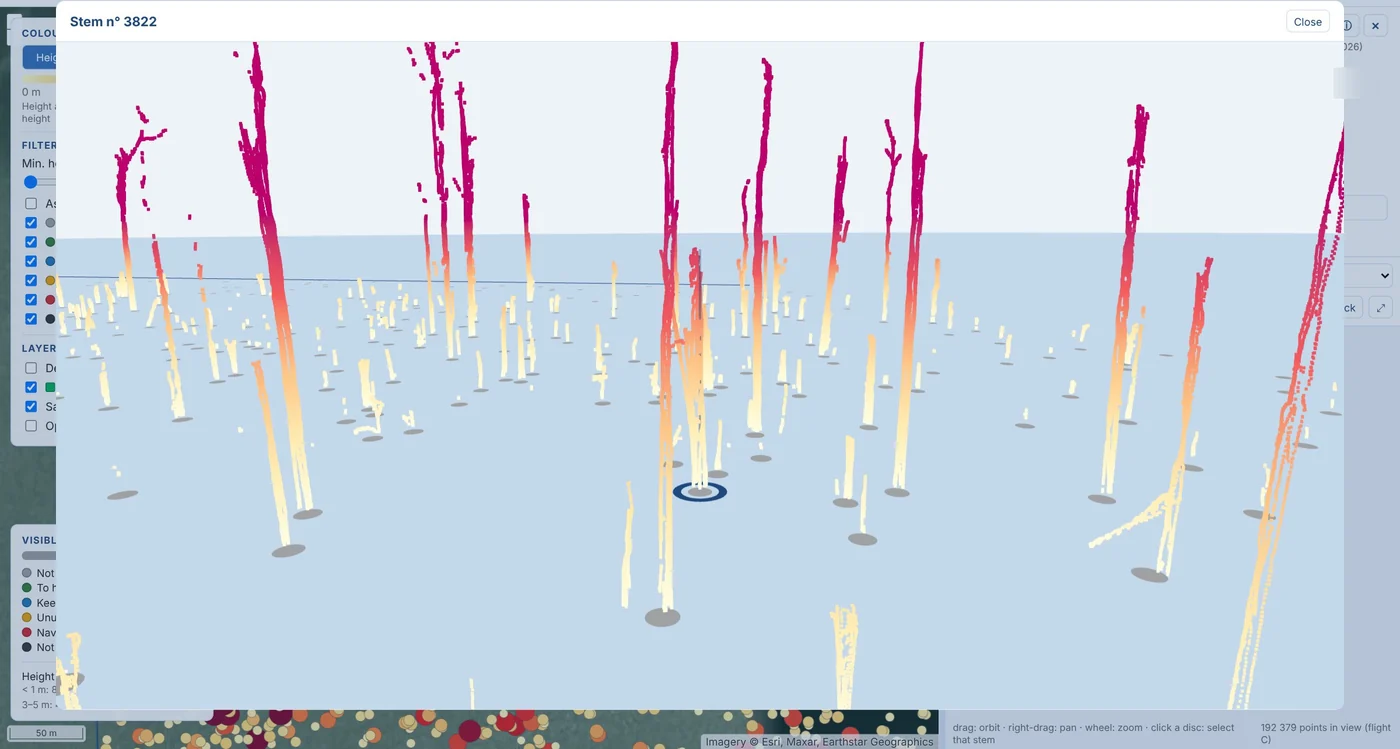
The client received the stem layers (shapefile, GeoJSON, KML for Google Earth, DXF, CSV), the point clouds of each flight with the number of every stem, and a web page that opens from the folder without any installation. It shows the map, opens each stem in 3D and in elevation, lets the user give it a status (to harvest, keep standing, navigation hazard…), a species, a field-measured diameter, and exports everything to a spreadsheet, a GIS or a GPS. The same number identifies each stem in every product.
And for the whole reservoir?
On the basis of this day we recommend a two-level approach: an inventory at 90 m and 1,000 kHz over all sectors, which locates 92 % of the stems and 96 % of those taller than one metre at about 220 ha per flight hour, in the order of 500 ha per day on the lake, then 60 m flights over the blocks to be harvested, for the most complete count, heights to within 15 cm and diameters. The harvest of the test block will allow the LiDAR diameters to be checked against measured trunks before the method is applied at scale.
The method carries over to other places where the ground cannot be reached: reservoirs, flooded areas, mangroves, forest inventories in difficult terrain.
Technical sheet
- Site: Petit-Saut reservoir (French Guiana), 46 ha test block, water level 31.10 m NGG77 on the day
- Date: 22 October 2026, one day, five LiDAR flights and two photographic flights
- Aircraft and sensors: DJI Matrice 400, Zenmuse L3 (LiDAR, 350 and 1,000 kHz), Zenmuse P1 (45 Mpx, 24 mm)
- Positioning: PPK against a Trimble R2 reference station, no ground control point; RGFG95 / UTM 22N, NGG77
- Processing: DJI Terra, Sentinel stem detection and measurement chain, Agisoft Metashape (photo trials)
- Results: 4,049 confirmed stems, 85 per hectare, height above water for each, base diameter for 88 %
- Deliverables: assessment report, SHP, GeoJSON, KML, DXF, CSV, LAZ point clouds, web inventory page